I am a fourth-year PhD student in the Berkeley Artificial Intelligence Research (BAIR) group, specializing in Robotics and Artificial Intelligence. My research interests include robot learning for manipulation, real-to-sim-to-real, and reward function learning. Broadly, I focus on developing systems and algorithms that enable real-world robots to learn and improve on practical manipulation tasks.
I am advised by Ken Goldberg in the AUTOLab and am supported by the NSF GRFP. I graduated Summa Cum Laude with a B.S.E. in Electrical Engineering from the University of Michigan, Ann Arbor in 2023.
-
Frontier LLMs write robot control code at a third of human domain-expert reliability. CaP-Agent0 closes the gap: a training-free harness beats post-trained VLAs with no task-specific data, and RLVR lifts a 7B coder from 20% to 72% success, transferring to a real Franka robot.
-
Scaling robot data without robot hardware Real2Render2Real CoRL 2025Oral· top 5.7% of submissions
One smartphone scan and one human demo video become thousands of robot demos, with no dynamics simulation or teleoperation. Across 1,050 real-robot trials, policies trained on R2R2R data match teleop-trained ones at 1/27 the collection time.
-
Self-supervised reward model that filters robot training data. +78% T-shirt folding and +60% bottle-in-bin throughput on real robots; sim evals reproducible end to end from public code and checkpoints.
SARM2: Multi-Task Stage Aware Reward Modeling for Self Improving Robotic Manipulation
Low Cost I2RT YAM Robot Teaching Devices
Weekend project - Open source hardware and software for I2RT YAM leader arms.
Realtime Robots Control Package
Open source software package to control real-world robot arms including the I2RT YAMs, Franka Panda.
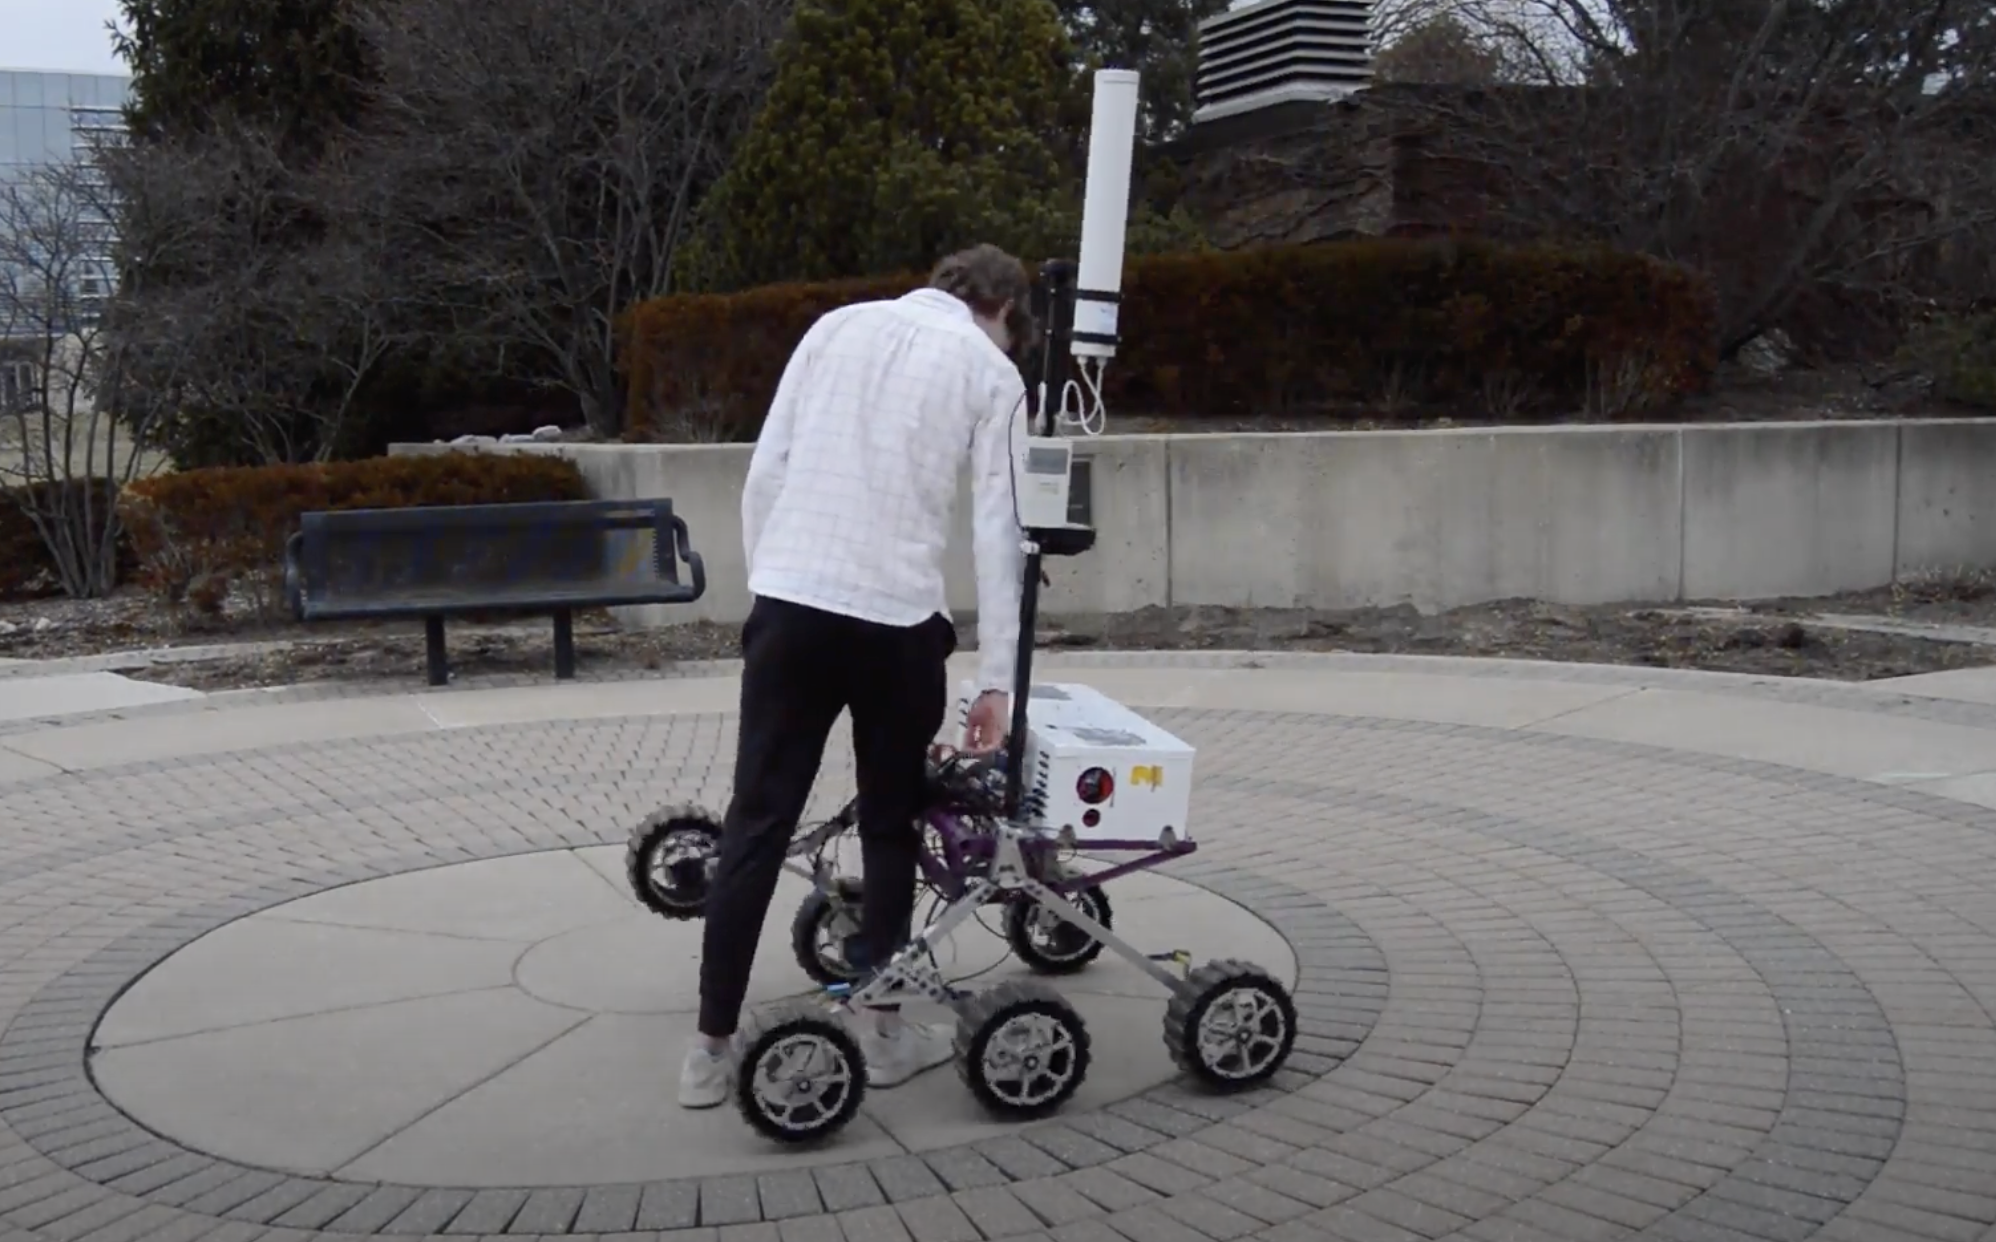
2023 Michigan Mars Rover - Dahlia
Affiliation: Team Lead - RF Wireless Communications for University of Michigan Mars Rover team
Dahlia received a System Acceptance Review score of 92.21/100.
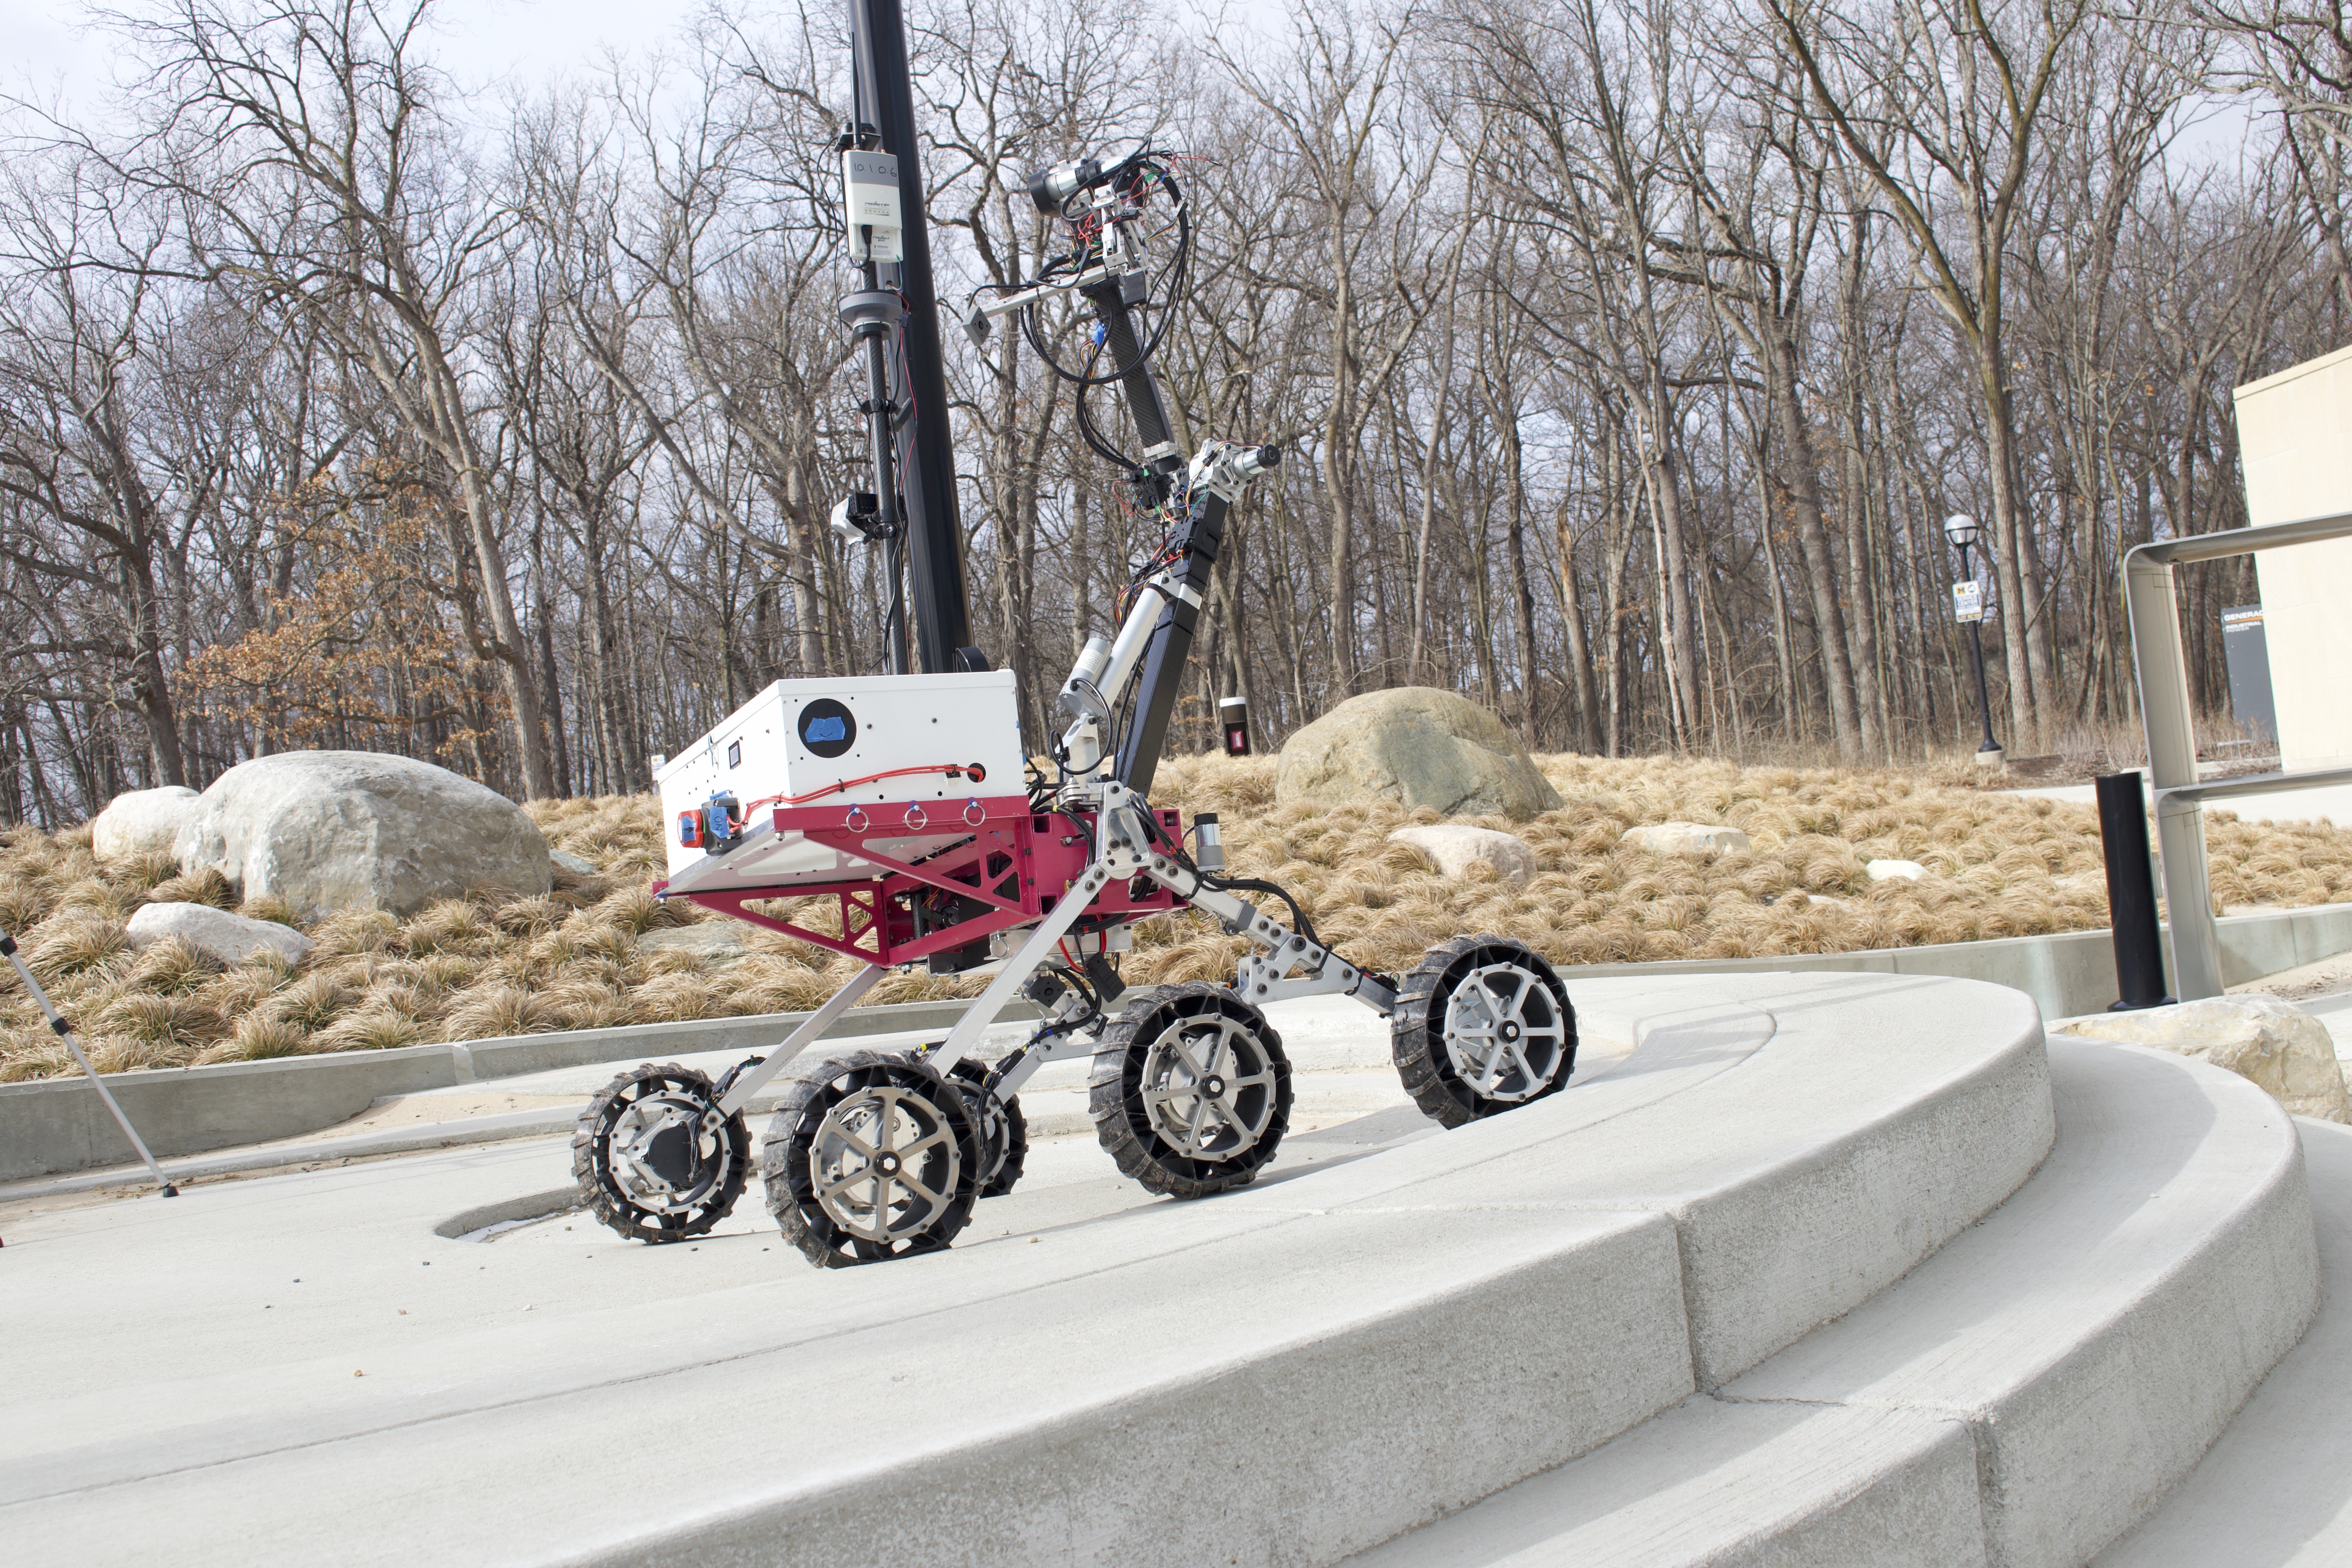
2022 Michigan Mars Rover - Rosie
Affiliation: Team Lead - RF Wireless Communications for University of Michigan Mars Rover team
Rosie received a System Acceptance Review score of 90.97/100 and finished 1st place at the URC and CIRC competitions.
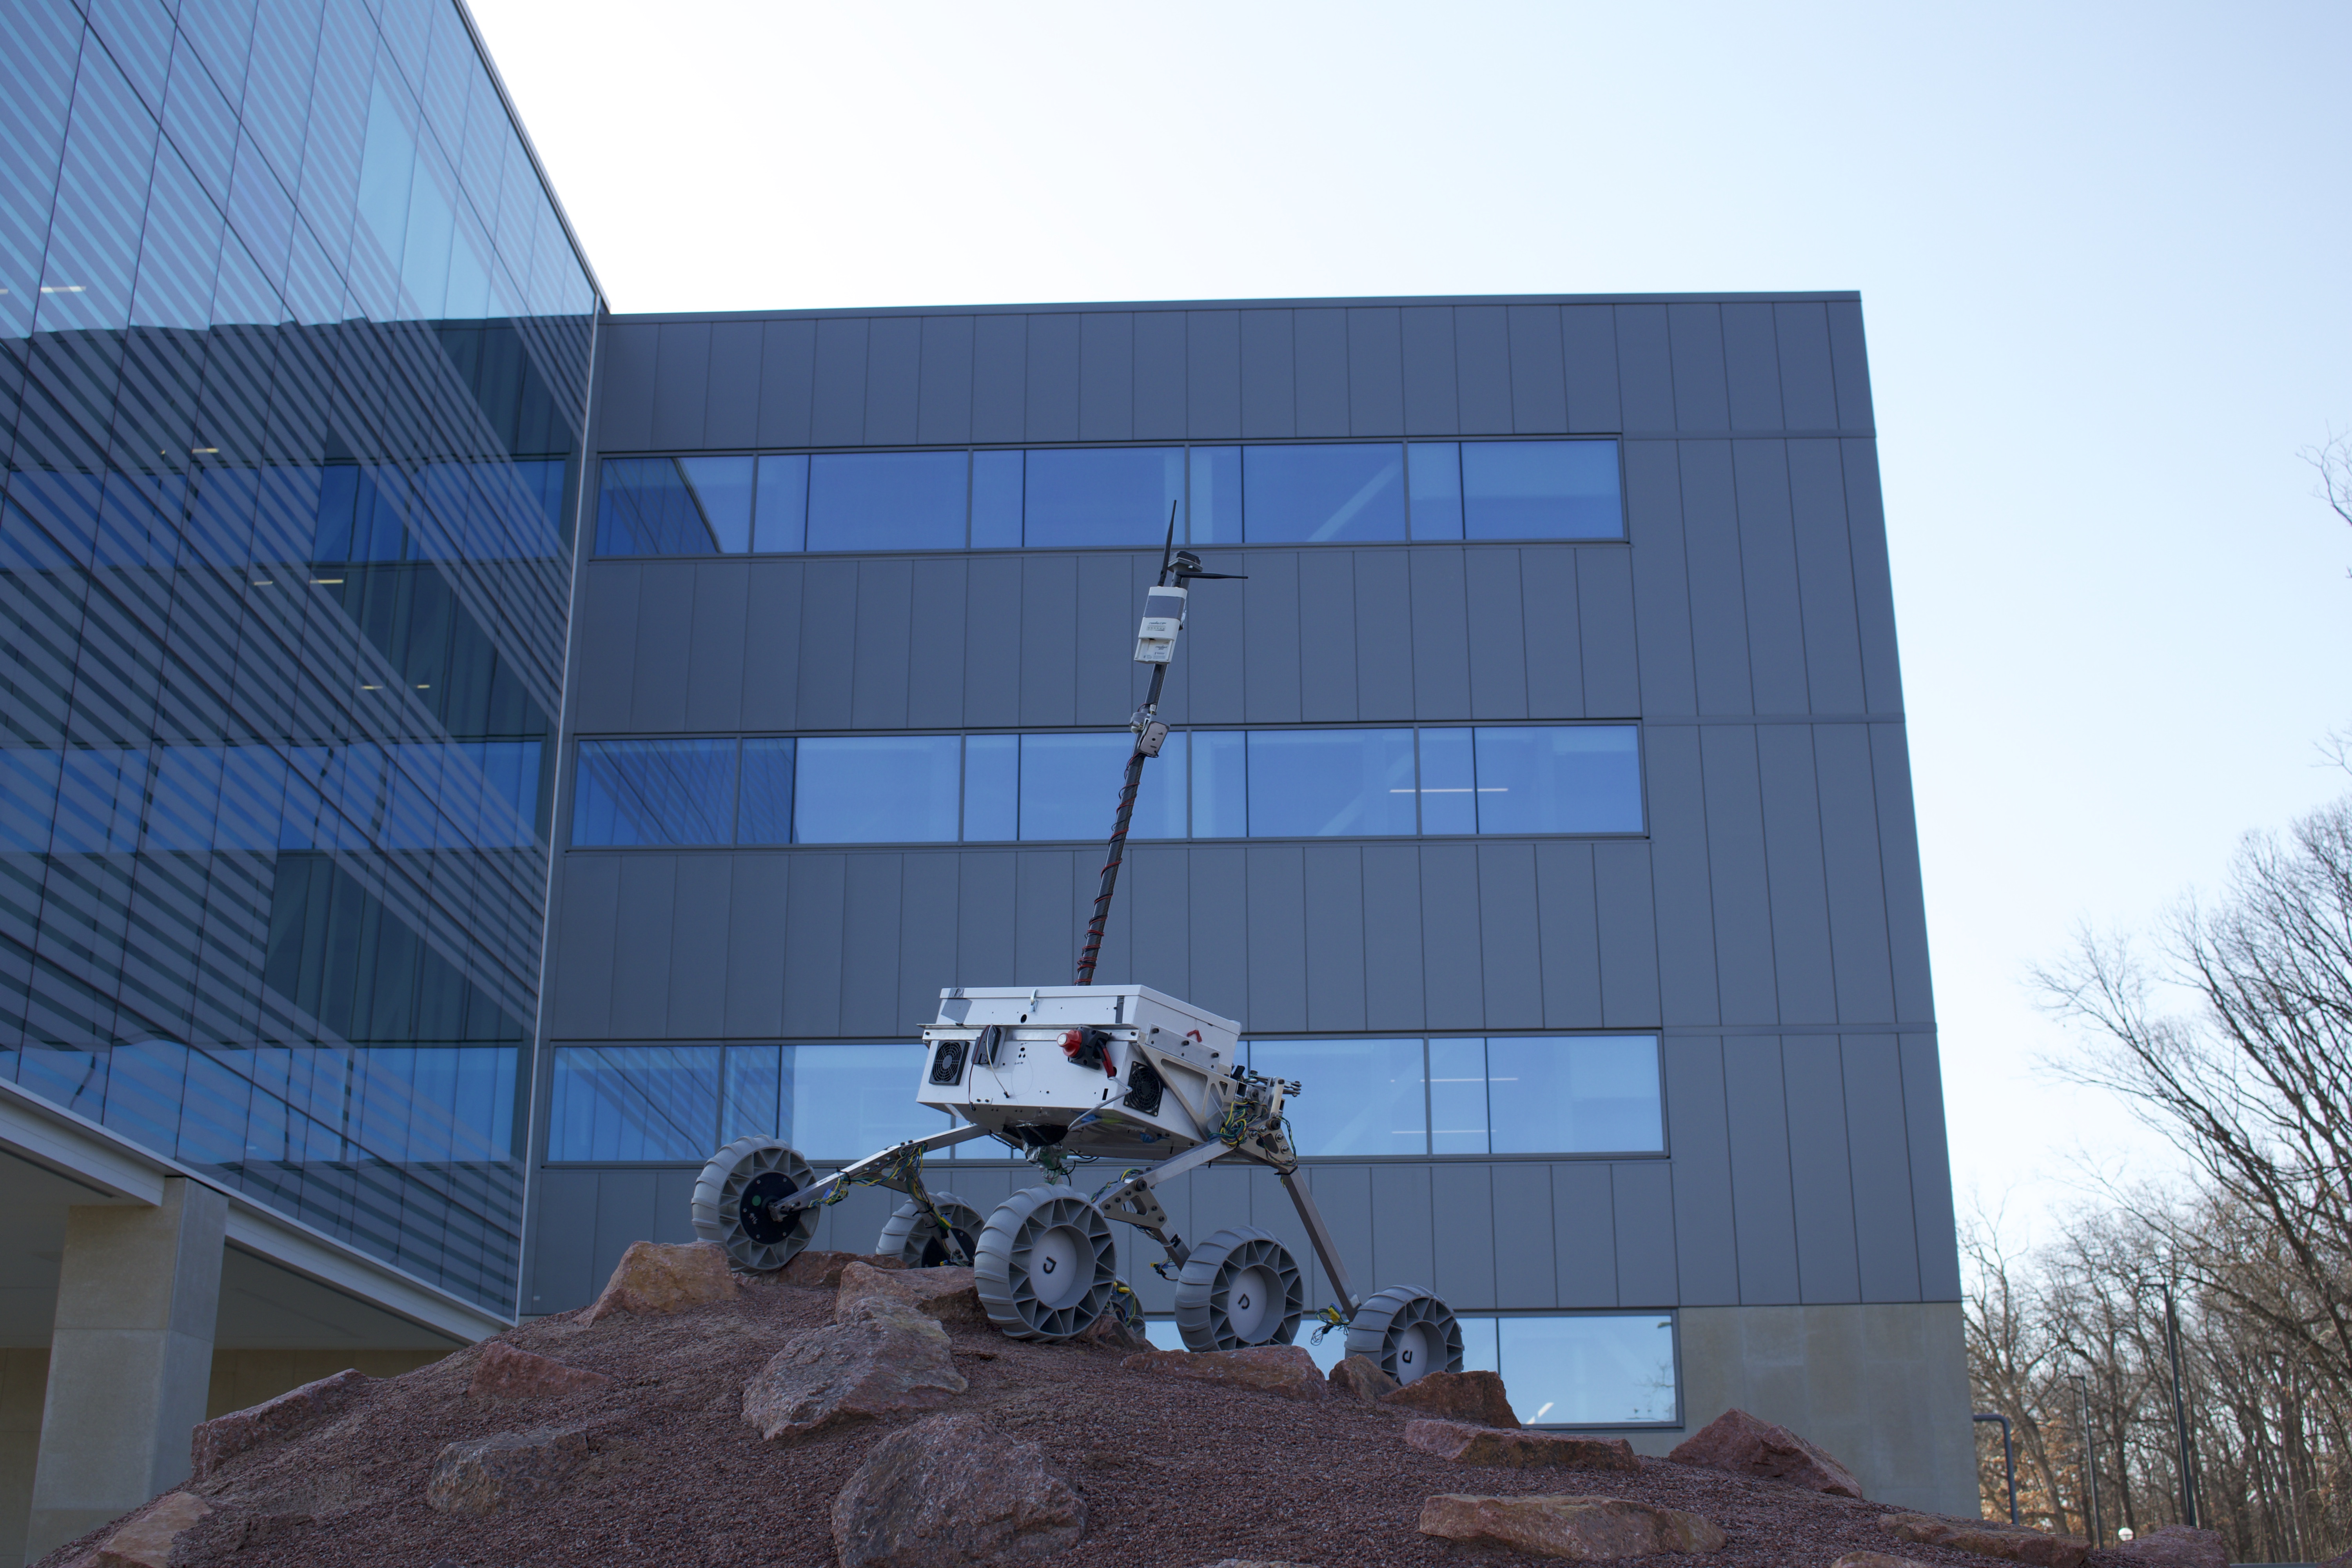
2021 Michigan Mars Rover - Blue
Affiliation: Robotic Arm Hardware Designer for University of Michigan Mars Rover team
Though in-person competition was cancelled due to the pandemic, Blue received a System Acceptance Review score of 93.09/100.
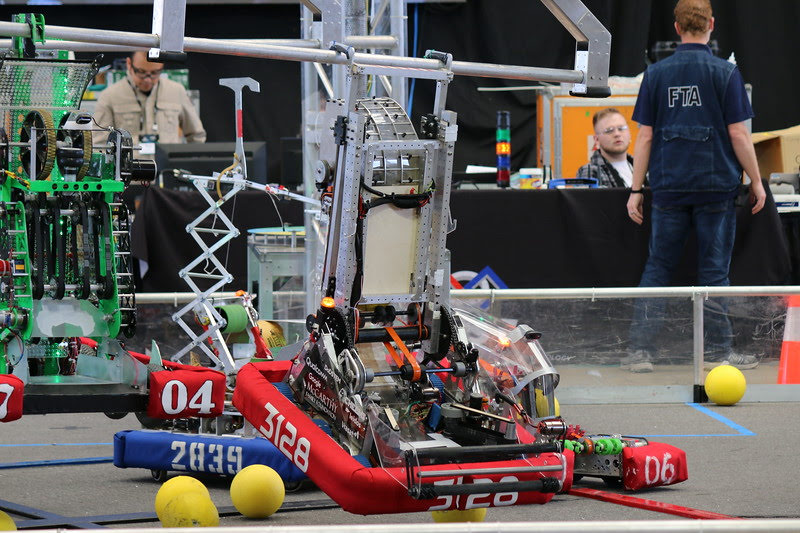
2020 FRC Robot - Cheems
Affiliation: Team Lead - Mechanical Design and Fabrication for 3128 Aluminum Narwhals.
Season cut short due to the pandemic.
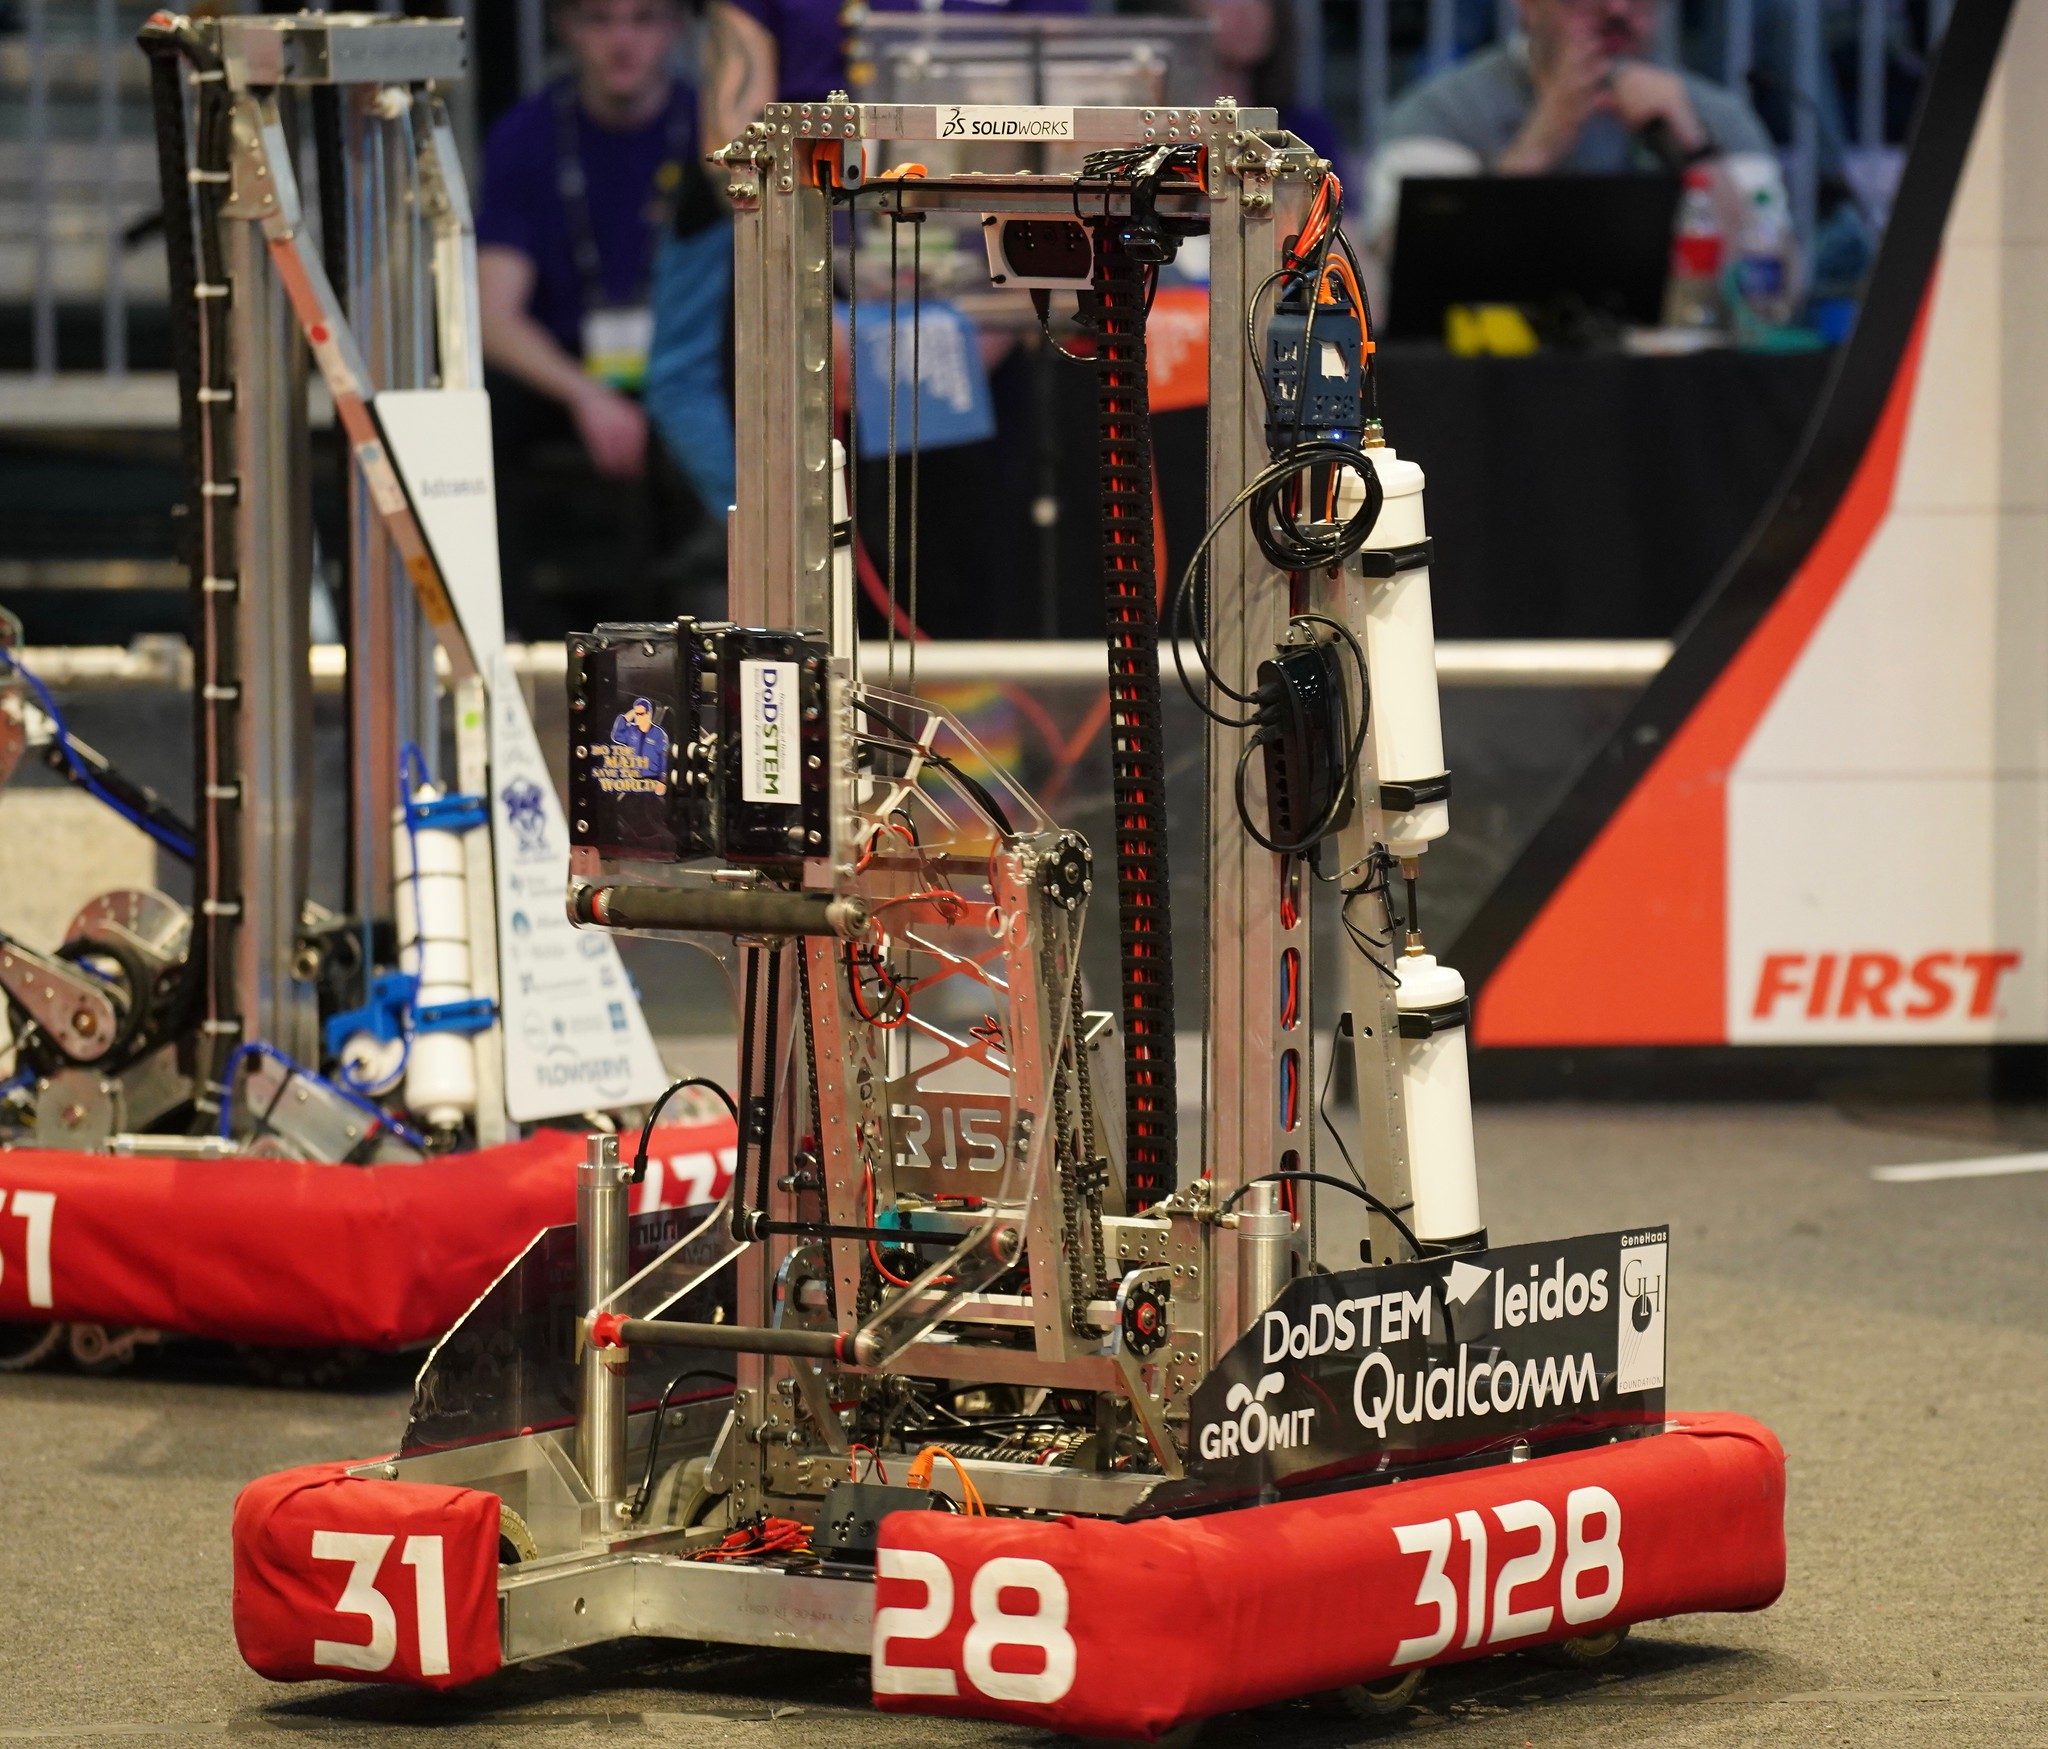
2019 FRC Robot - Gromit
Affiliation: Team Lead - Mechanical Design and Fabrication for 3128 Aluminum Narwhals.
Ranked 1st seed at Monterey Bay Regional - Alliance Captain at the FRC World Championship in Houston.
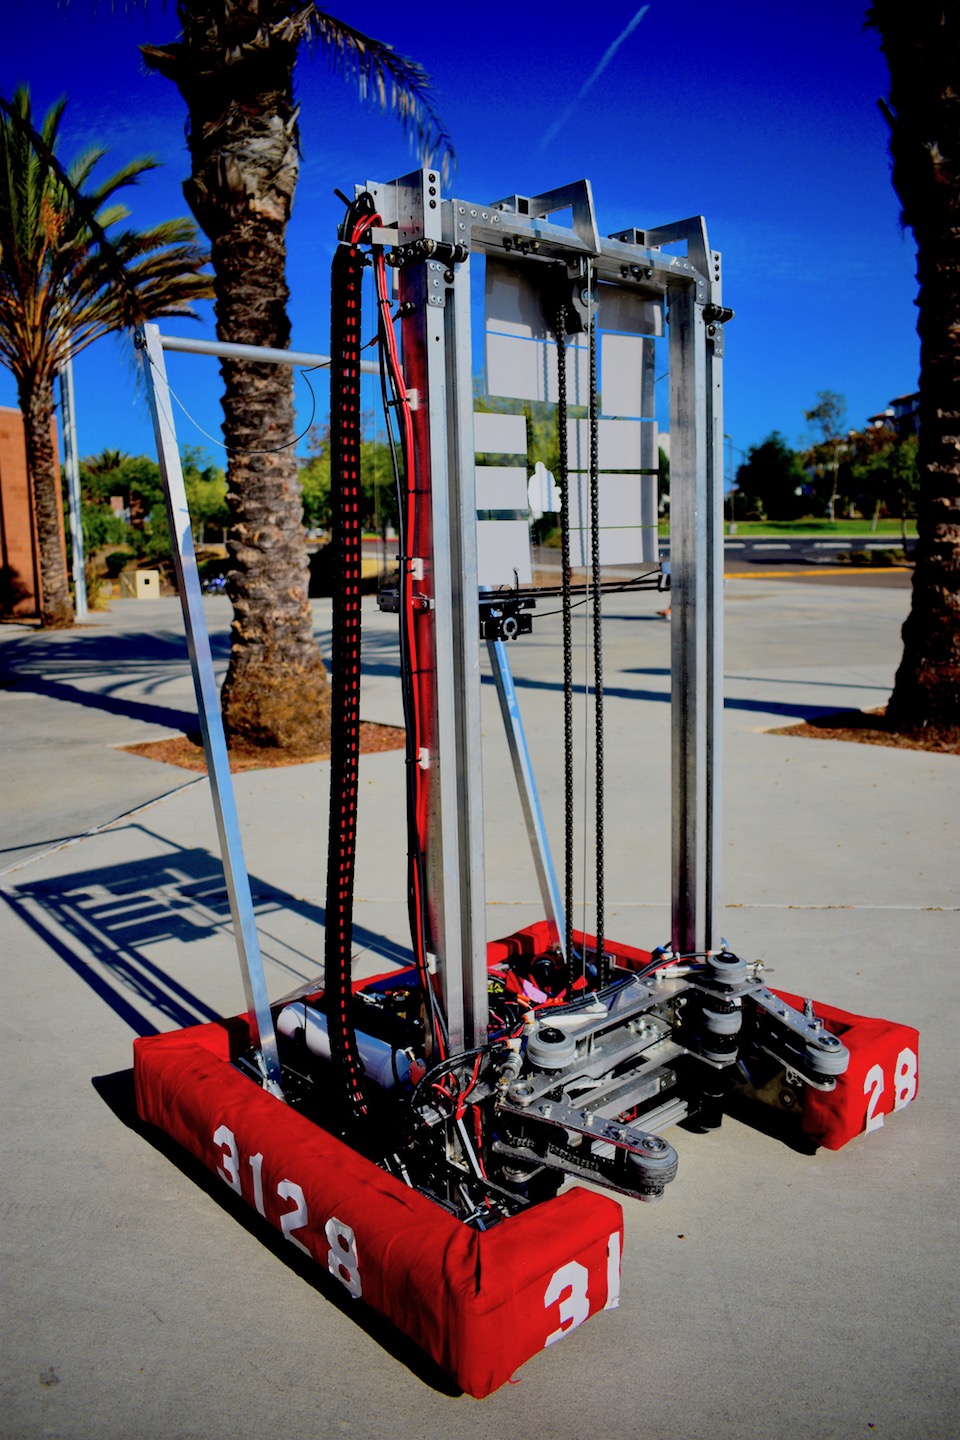
2018 FRC Robot - Guido
Affiliation: Member of Mechanical Design and Fabrication for 3128 Aluminum Narwhals.
Joined the first seeded team in World Championship - eliminated in finals matches.
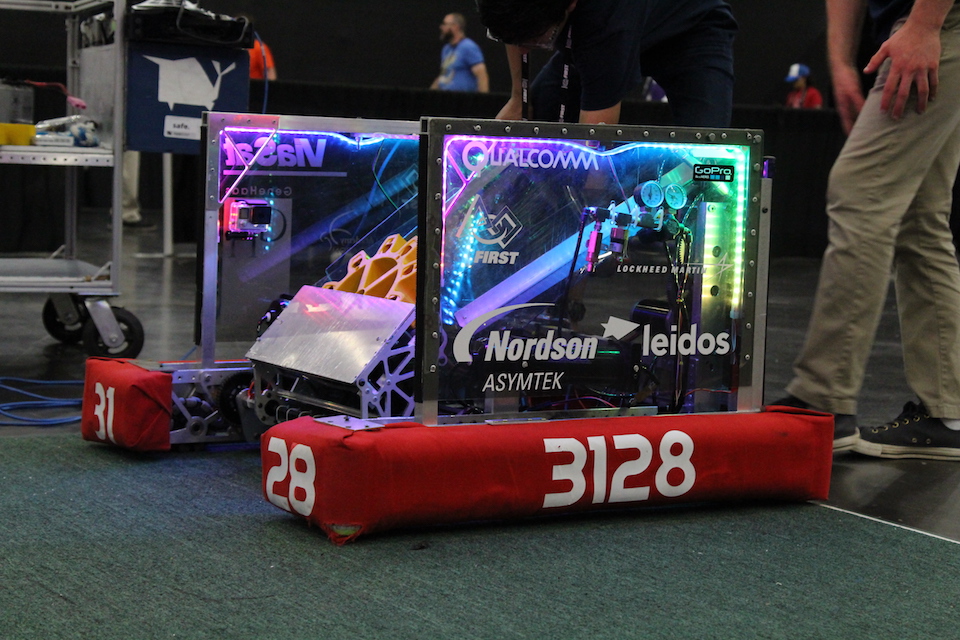
2017 FRC Robot - Ferb
Affiliation: Member of Mechanical Design and Fabrication for 3128 Aluminum Narwhals.
Finalist Alliance Captain at San Diego Regional - Advanced to FRC World Championship in Houston.